
Amr Mousa
Senior AI Research Engineer and PhD Student
Virtual Vehicle Research GmbH
University of Manchester
About Me
I’m a PhD student at the University of Manchester, working with the supervision of Richard Allmendinger and Michele Caprio. My research dives deep into the challenge of making Reinforcement Learning (RL) thrive in non‑stationary environments—an area that’s key to bringing RL out of the lab and into the messy, unpredictable real world.
Alongside my academic journey, I work at Virtual Vehicle Research GmbH in Graz, Austria, as a Senior Research and Development Engineer. There, I lead projects designing RL policies for legged robots in search‑and‑rescue missions and develop intelligent agents for energy management in plug‑in hybrid vehicles—blending cutting‑edge AI with greener, smarter mobility.
- Reinforcement Learning
- Self-Supervised Learning
- Representation Learning
- Robotics
- Automotive and Aerospace
-
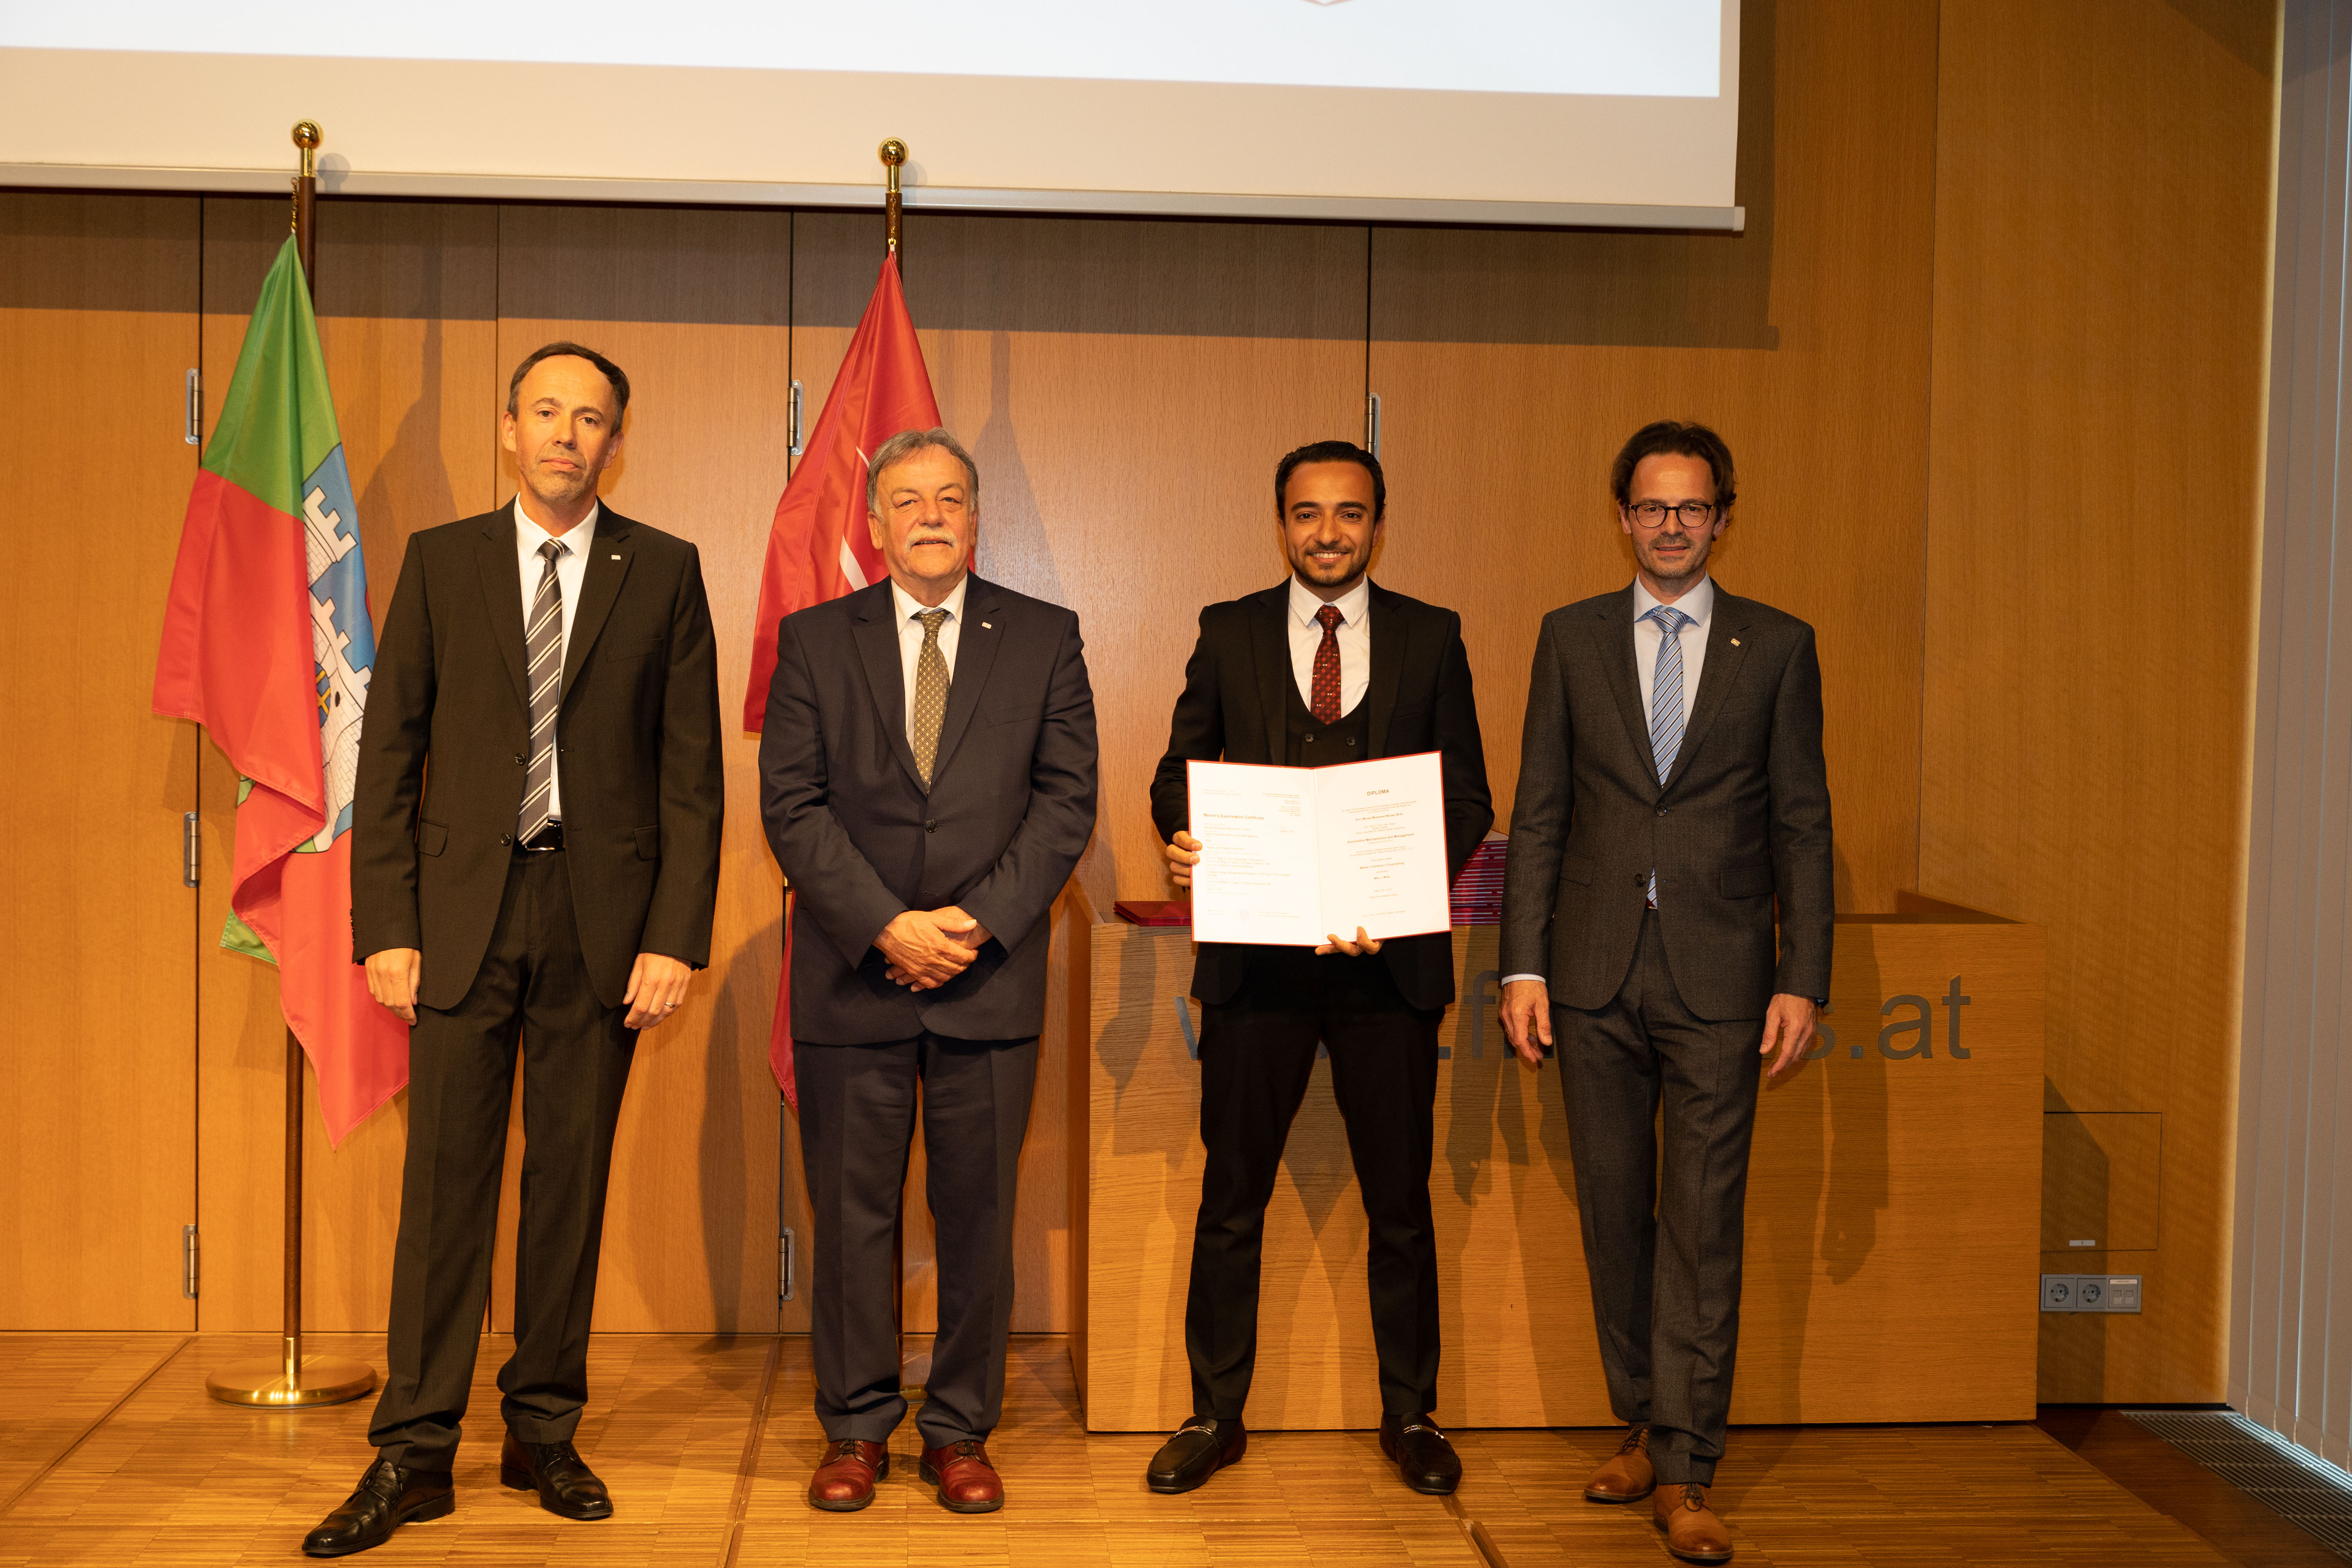
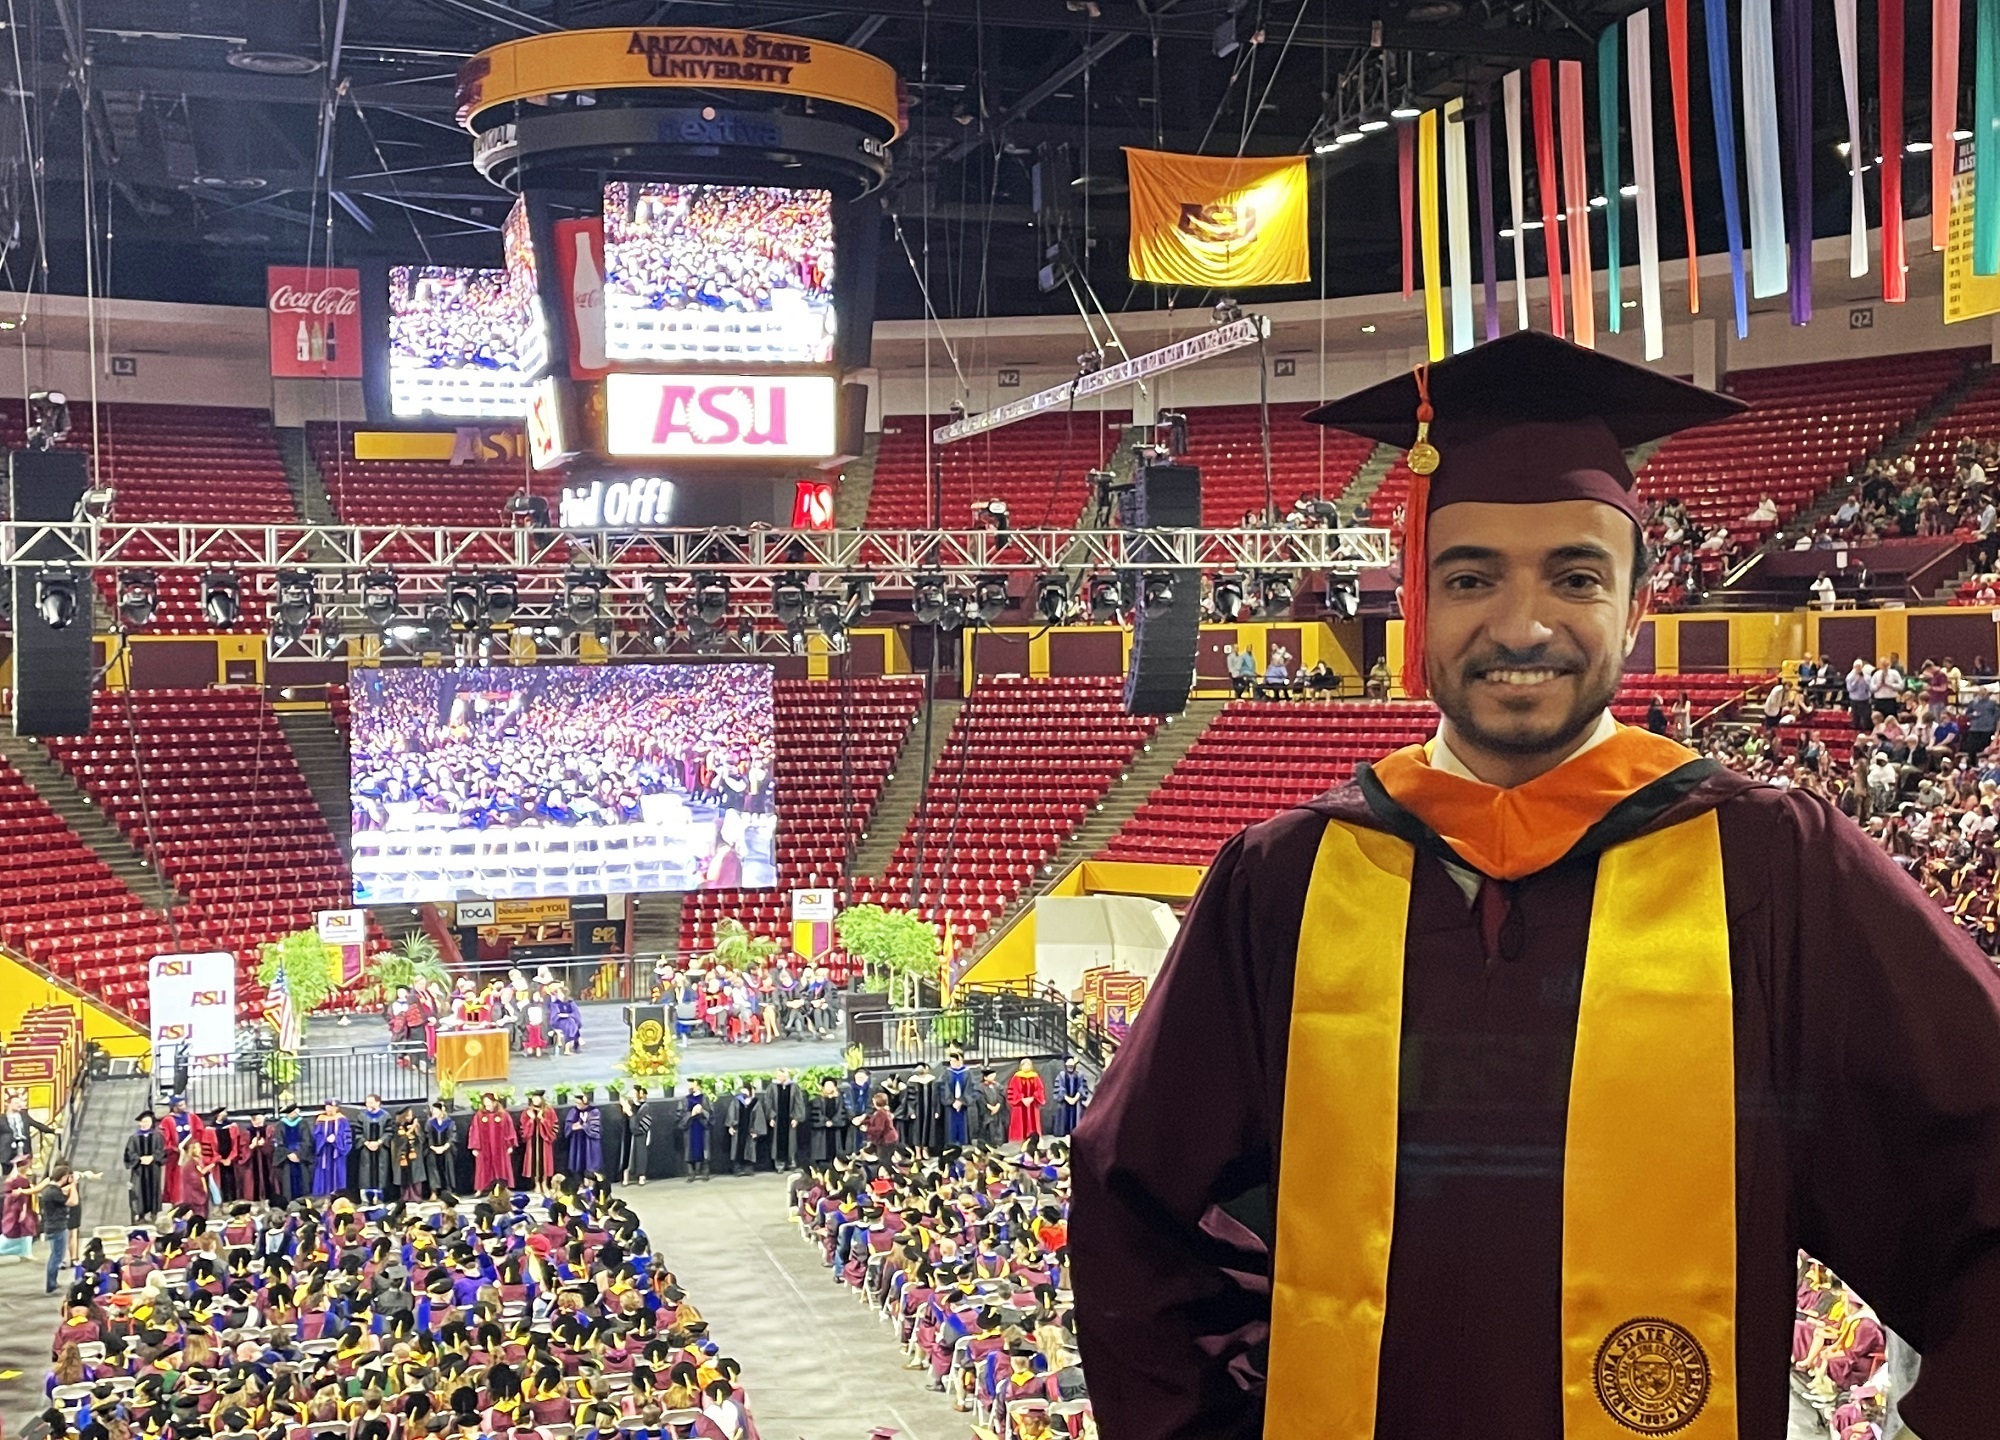
Master of Engineering Management, 2022
Arizona State University
-
Master of Automotive Mechatronics, 2021
FH Oberösterreich
-
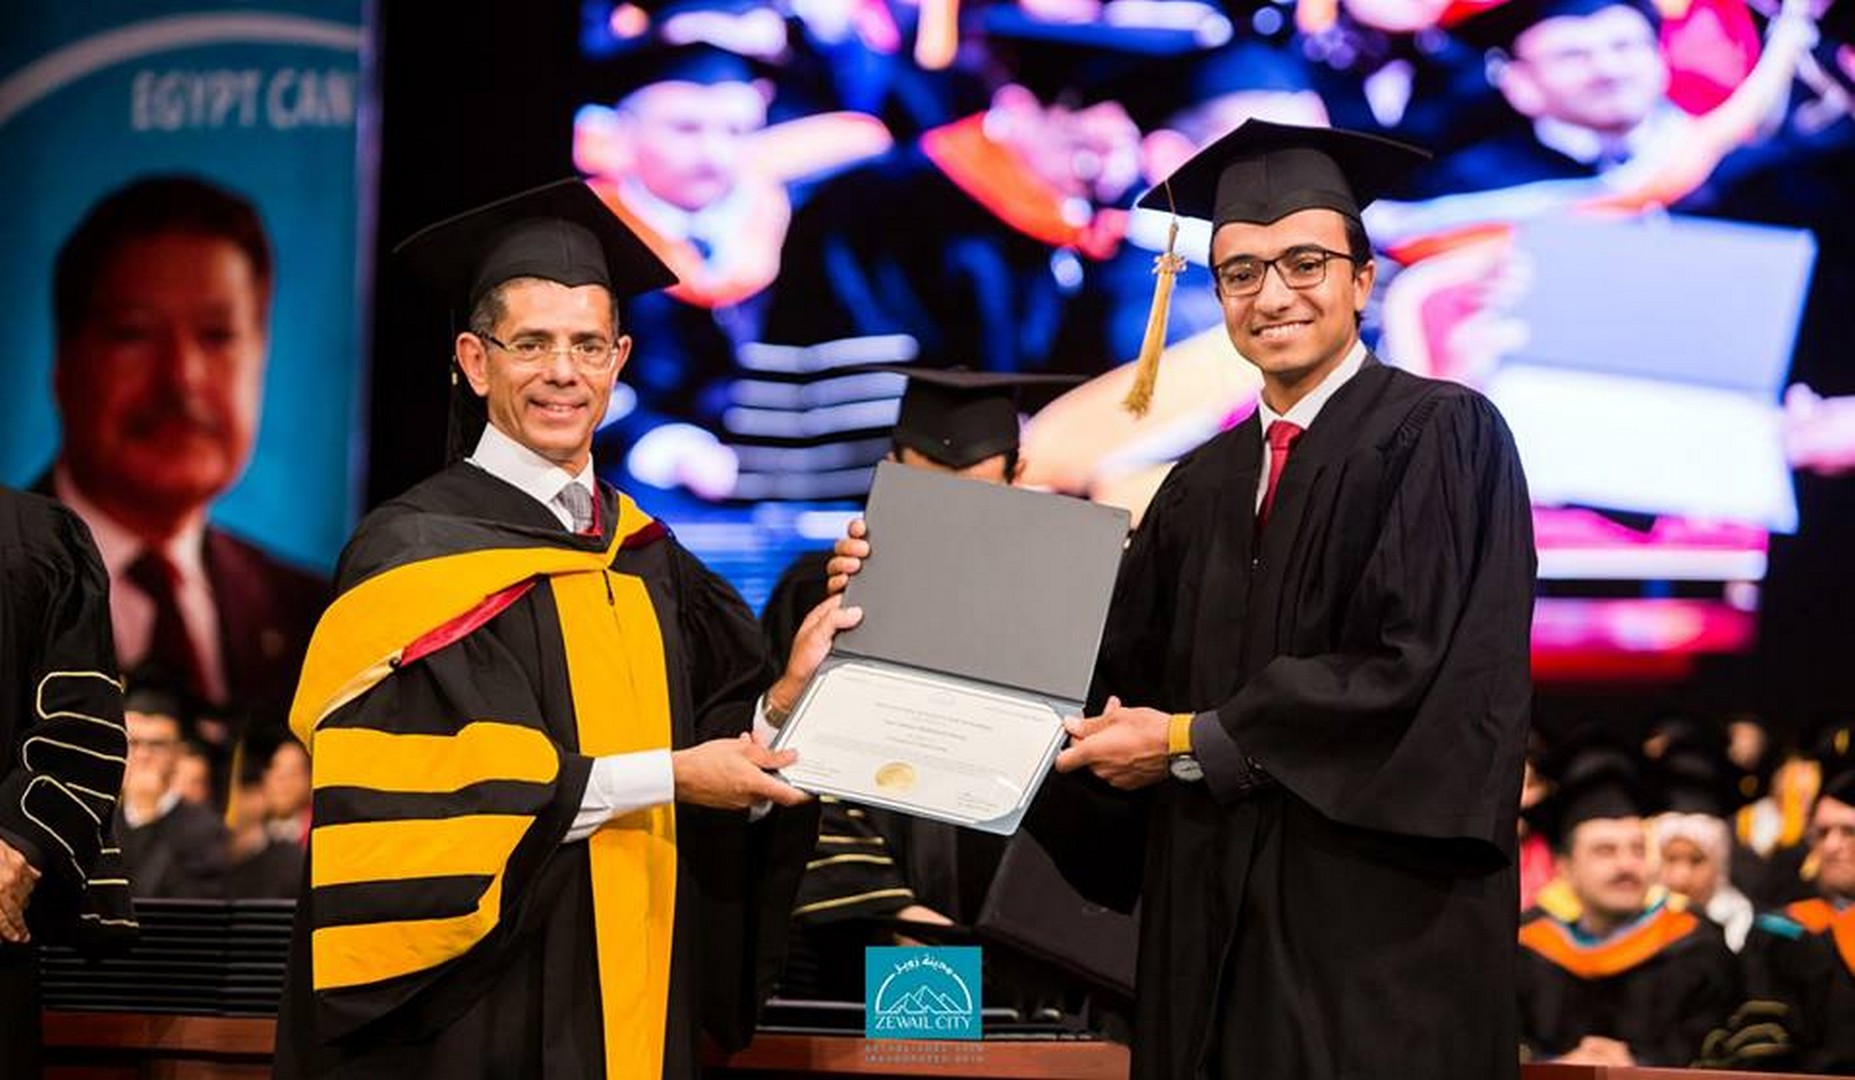
Bachelor of Aerospace Engineering, 2018
Zewail City, Egypt
News
PROMO Project Page and Web Demo Are Live
Oct 1, 2026
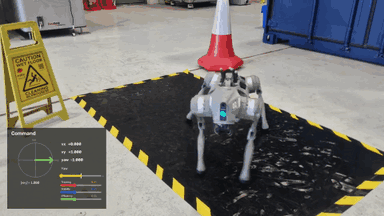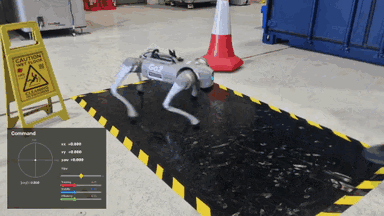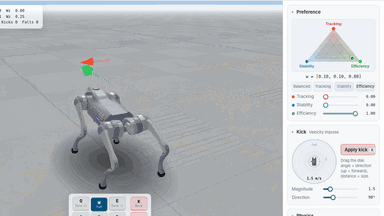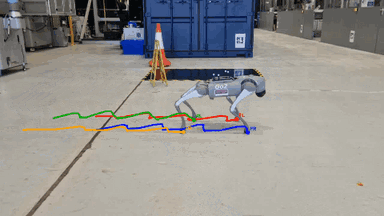
Our work on preference-conditioned multi-objective locomotion, PROMO, now has a 🌐 project page with videos and the full simulation and hardware results. You can also 🕹️ drive the policy in your browser and change the preference live. The manuscript is under review at IEEE Transactions on Robotics (T-RO).
PROMO at the HART Workshop, TAROS 2026
Sep 10, 2026
I presented PROMO — semantic preference conditioning as an interface for human–robot alignment — at the HART workshop at TAROS 2026. See the 🌐 project page for videos and results.
Finalist for the BAE Systems PhD Award
Sep 3, 2026
I was nominated by the University of Manchester to represent the university in the BAE Systems PhD Award and have reached the finalist stage.
Global Talent Visa Endorsement
Aug 15, 2026
I got endorsed for the Global Talent visa under exceptional promise track by the Royal Academy of Engineering and was granted the visa in August 2026.
Highlighted Work
Working Experience

- Teaching: Teaching in the Department of Computer Science and the Alliance Manchester Business School.
- Master’s Thesis Supervision: Mentoring graduate students in several research areas including Statistics, Reinforcement Learning and robotics.
- Research Assistant: Contributing to data analysis projects and research initiatives across two academic semesters
- Peer Review: Serving as reviewer for prestigious conferences and journals including NeurIPS and other top-tier publications in AI and robotics

Key projects include:
-
Developing robust RL-based locomotion policy for legged robots:
Using Meta-Reinforcement Learning to develop a locomotion policy for the quadruped robot -Unitree Go1- to be able to robustly navigate different environments for survival and rescue missions.
-
RL-based Energy Management Strategy for P2-PHEVs:
Implementing a novel A3C agent that outperformed the existing rule-based control strategy and was integrated into the vehicle HCU for testing in HiL and ViL. The project resulted in two publications and a patent.

Key projects include:
-
Adaptive interiors control with a German OEM - Project Lead:
Developing an imitation learning RL agent that learns and predicts the driver preferences based on the driver mood, driving behavior and vehicle situation.
-
RL-based Thermal Management for Battery Electric Vehicles:
Improving the vehicle energy consumption by utilizing the heat sources to meet the cabin comfort requirements, powertrain, and battery optimal efficiencies.

See Employer Letter
Honors


Certificates


Gallery
Highlighted imagery capturing moments from conferences and academic gatherings



Contact
- amr.mousa@postgrad.manchester.ac.uk
- Alliance Manchester Business School, Booth Street West, Manchester, M15 6PB, United Kingdom